> ## Documentation Index
> Fetch the complete documentation index at: https://dragonwingdocs.qualcomm.com/llms.txt
> Use this file to discover all available pages before exploring further.
# Enable 2D lidar SLAM with cartographer_ros
The 2D lidar SLAM sample application is based on `Cartographer`, which is capable of completing indoor map construction and localization based on 2D lidar sensors. It's suitable for indoor navigation of robots.
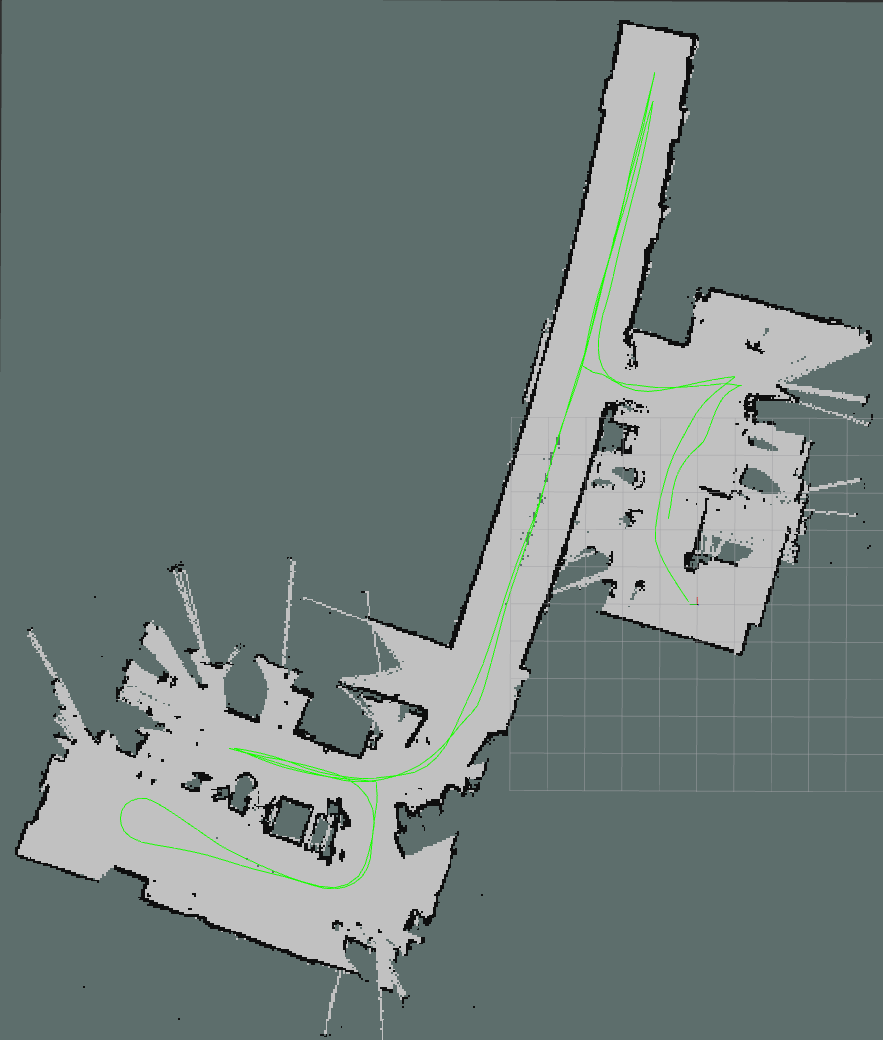
Figure: Sample results of 2D lidar SLAM
## Pipeline flow for `2D lidar SLAM`

Figure: Pipeline flow for 2D lidar SLAM
## ROS nodes used in the 2D lidar SLAM pipeline
| **ROS node** | **Description** |
| :--------------------------------- | :-------------------------------------------------------------------------------------------------------------------------------------------------------------------------------- |
| `cartographer_node` | Receives `/scan` and `/odom` topics, executes mapping, localization, and saves the map or queries the relocation status. The node is based on the ROS service `qrb_slam_command`. |
| `cartographer_occupancy_grid_node` | Receives map-related topics sent by the `cartographer_node` and publishes a ROS standard map (`/static_map`). |
## ROS topics/services used in 2D lidar SLAM
Table: ROS topics used in 2D lidar SLAM
| ROS topic |
Type |
Published by |
| `/tracked_pose` |
`geometry_msgs.msg.PoseStamped` |
`cartographer_node` |
| `/tf` |
`tf2_msgs.msg.TFMessage` |
`cartographer_node` |
| `/submap_list` |
`cartographer_ros_msgs.msg.SubmapList` |
`cartographer_node` |
| `/scan_matched_points2` |
`sensor_msgs.msg.PointCloud2` |
`cartographer_node` |
| `/map` |
`nav_msgs.msg.OccupancyGrid` |
`cartographer_occupancy_grid_node` |
Table: ROS services used in in 2D lidar SLAM
| ROS service |
Type |
Provided by |
| `/qrb_slam_command` |
`qrb_ros_slam_msgs.srv.SlamCommand` |
`cartographer_node` |
## Prerequisites
* You have **Set up the device** according to [Set up the environment for running sample applications](./set-up-env-for-sample-app).
* Connect the power supply and USB port of RPLIDAR A3M1.
## Run out-of-the-box `2D lidar SLAM`
**Note** The following configuration applies exclusively to Qualcomm’s robot base. If you are using a custom or third-party robot base, skip this configuration step and apply configurations appropriate to your own robot base.
1. Open a new terminal connect to the device.
```bash theme={null}
source /usr/share/qirp-setup.sh
export ROS_DOMAIN_ID=124
```
2. Select the robot base model.
* 0604 AMR: `robot_base` (default)
* Mini AMR: `robot_base_mini`
```bash theme={null}
export ROBOT_BASE_MODEL=robot_base_mini
```
3. (Optional) If you don't connect the ultrasonic sensor to the MCB, disable ultrasound emergency stop.
```bash theme={null}
vi /usr/ros/jazzy/share/qrb_ros_robot_base/config/[robot base model file]
# modify ultra_enable: false
```
4. Launch the robot base AMR.
```bash theme={null}
ros2 launch qrb_ros_robot_base robot_base.launch.py
```
In a new terminal, run the following commands.
```bash theme={null}
source /usr/share/qirp-setup.sh
export ROS_DOMAIN_ID=124
ros2 launch rplidar_ros rplidar_a3_launch.py
```
In a new terminal, run the following commands.
```bash theme={null}
source /usr/share/qirp-setup.sh
export ROS_DOMAIN_ID=124
ros2 launch cartographer_ros qrb_2d_lidar_slam.launch.py
```
In a new terminal, run the following commands.
```bash theme={null}
source /usr/share/qirp-setup.sh
export ROS_DOMAIN_ID=124
chmod 777 /usr/ros/jazzy/share/cartographer_ros/scripts/qrb_slam_service_request.sh
bash /usr/ros/jazzy/share/cartographer_ros/scripts/qrb_slam_service_request.sh
```
In the terminal opened in the preceding step, use the keyboard to send control commands, such as starting the mapping process.