> ## Documentation Index
> Fetch the complete documentation index at: https://dragonwingdocs.qualcomm.com/llms.txt
> Use this file to discover all available pages before exploring further.
# Enable basic RPLIDAR handling with rplidar-ros
> The rplidar-ros2 sample application provides basic device handling for the 2D laser scanner RPLIDAR A1/A2/A3/S1/S2/S3.
## Pipeline flow for `rplidar_ros`
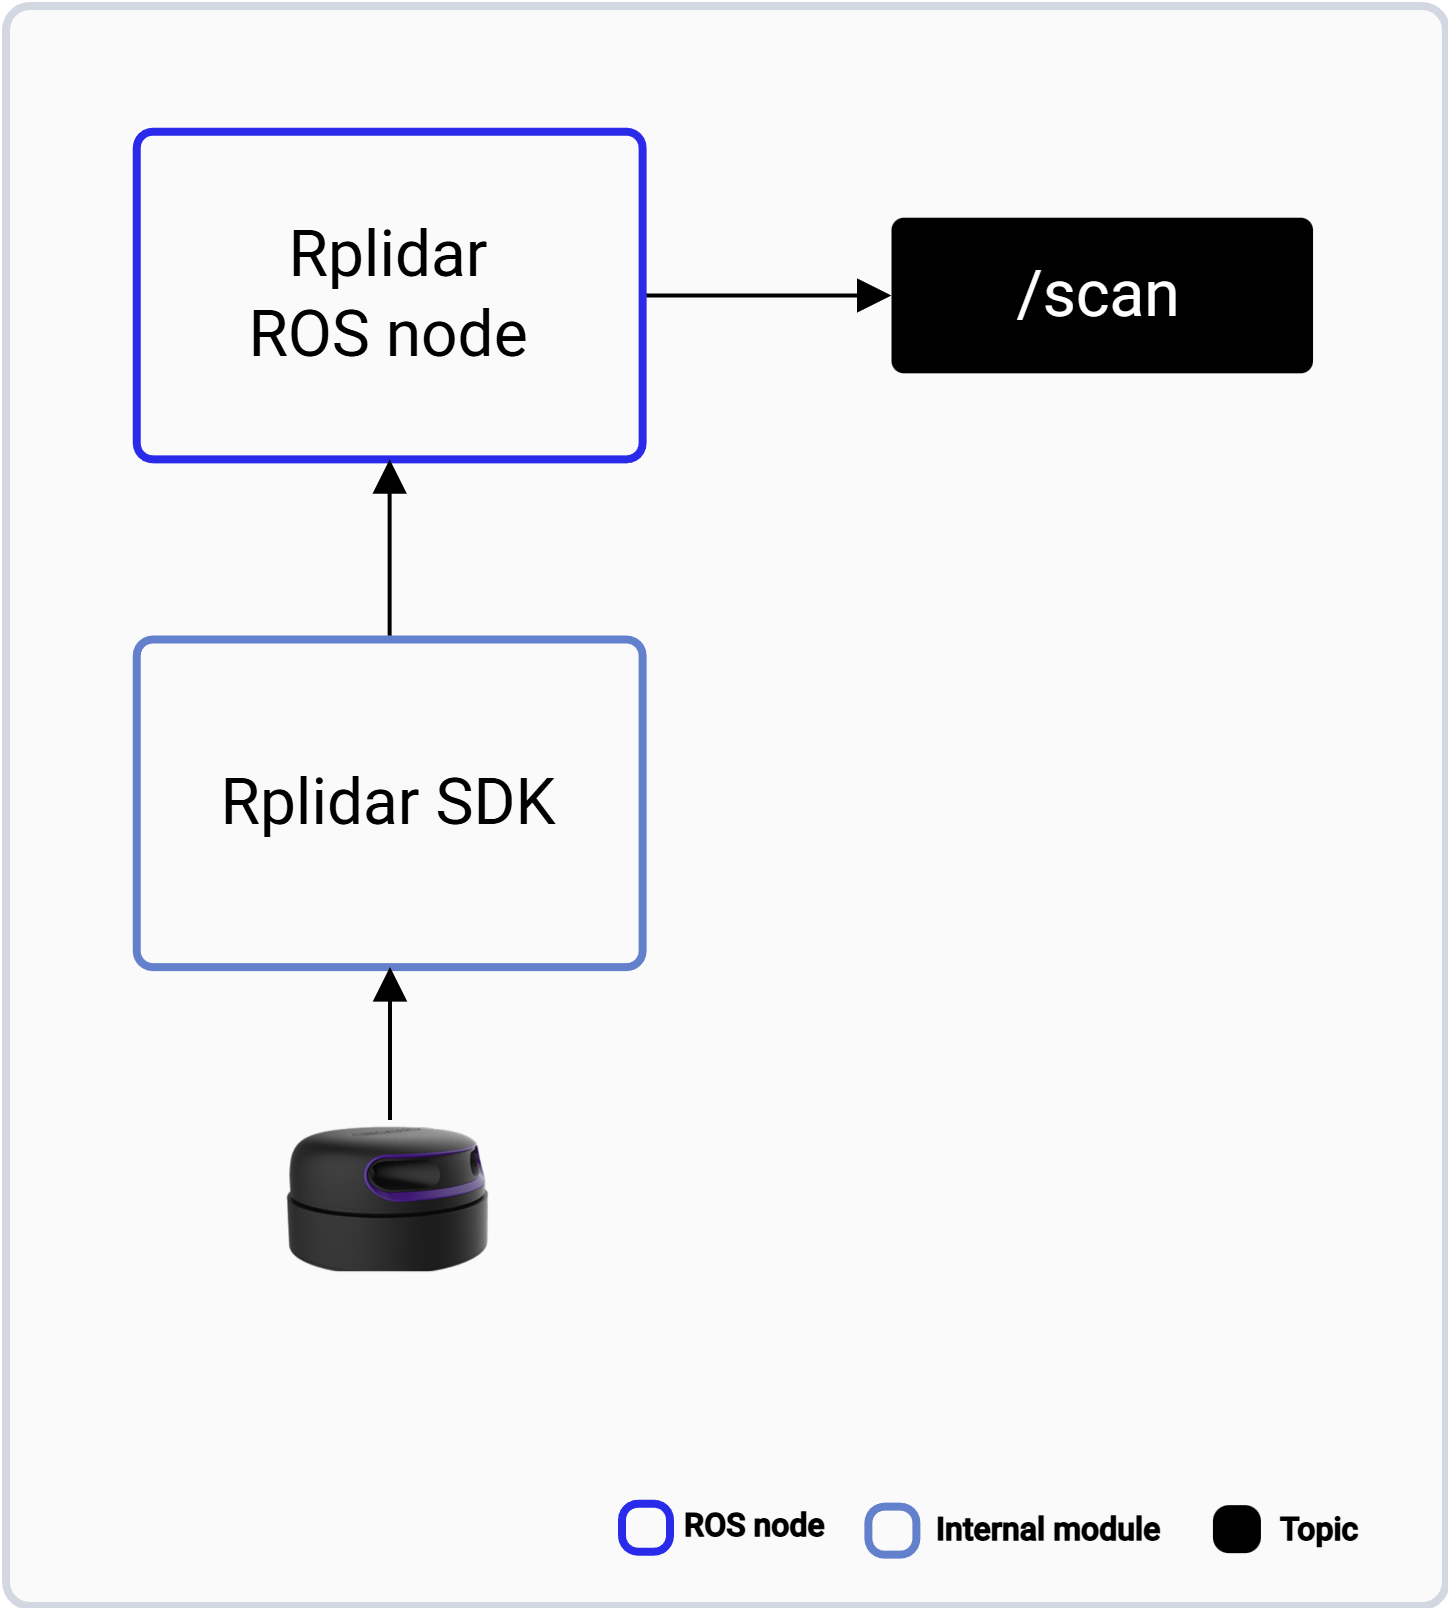
The following figure shows the pipeline flow for the `rplidar-ros2` sample. The sample gets the driver data from the RPLIDAR SDK, and then publishes the `/scan` topic.
 ## ROS topics used in the `rplidar-ros2` pipeline
The following table lists the ROS topics used in the `rplidar-ros2` pipeline, with the message type and the publisher of each topic.
| ROS topic | Type | Published by |
| --------- | ------------------------------- | ------------------- |
| `/scan` | `` | `rplidar-ros2` node |
## Prerequisites
* You have set up the device, installed ROS2 Jazzy and the Qualcomm Intelligent Robotics (QIR) SDK on the device according to [Install the QIR SDK](./install-the-qir-sdk).
* Connect the power supply and USB port of RPLIDAR A3M1.
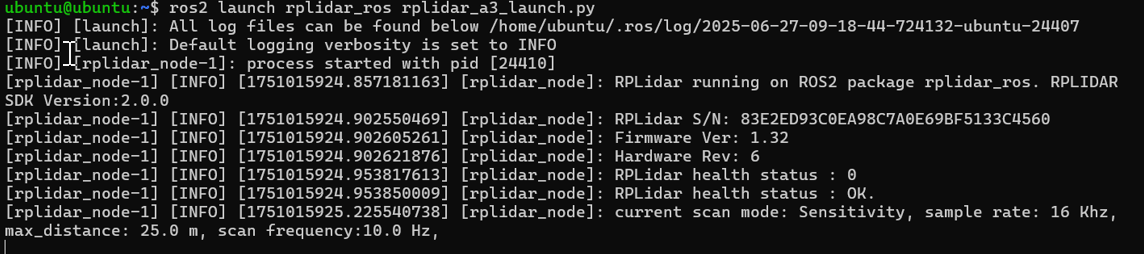
## Run out-of-the-box `rplidar-ros2`
```bash Launch the lidar ROS node theme={null}
source /opt/ros/jazzy/setup.bash
ros2 launch rplidar_ros rplidar_a3_launch.py
```
```bash List the ROS topics theme={null}
source /opt/ros/jazzy/setup.bash
ros2 topic list
```
```bash Echo the scan topic theme={null}
source /opt/ros/jazzy/setup.bash
ros2 topic echo /scan
```