> ## Documentation Index
> Fetch the complete documentation index at: https://dragonwingdocs.qualcomm.com/llms.txt
> Use this file to discover all available pages before exploring further.
# Evaluate ROS component performance with qrb_ros_benchmark
> qrb_ros_benchmark is a benchmarking tool designed for evaluating the performance of ROS components on Qualcomm robotics platforms. It provides reusable components for benchmarking various message types and ROS nodes, with a focus on zero-copy transport mechanisms.
`qrb_ros_benchmark` builds on [ros2\_benchmark](https://github.com/NVIDIA-ISAAC-ROS/ros2_benchmark) and extends it with specialized components for benchmarking QRB ROS transport types, including:
* QRB transport types (Image, IMU, PointCloud2)
* DMABuf transport types (Image, PointCloud2)
* Standard ROS message types
## Software structure
The following figure shows the software structure of `qrb_ros_benchmark`.
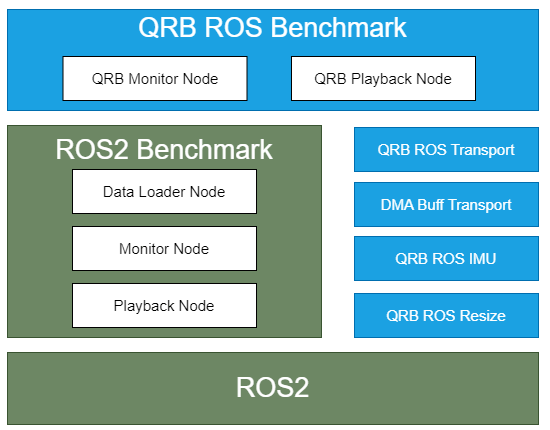 The basic usage is similar to [ros2\_benchmark](https://github.com/NVIDIA-ISAAC-ROS/ros2_benchmark) and the following are the exclusive message types supported by `qrb_ros_benchmark`:
**QRB transport types:**
* `qrb_ros/transport/type/Image`
* `qrb_ros/transport/type/Imu`
* `qrb_ros/transport/type/PointCloud2`
* `qrb_ros_tensor_list_msgs::msg::TensorList`
**DMABuf transport types:**
* `dmabuf_transport/type/Image`
* `dmabuf_transport/type/PointCloud2`
## Prerequisites
You have set up the device, installed ROS2 Jazzy and the Qualcomm Intelligent Robotics (QIR) SDK on the device according to [Install the QIR SDK](./install-the-qir-sdk).
## Run out-of-the-box `qrb_ros_benchmark`
```bash Install the packages theme={null}
sudo apt install ros-jazzy-qrb-ros-benchmark
```
```bash Create the launch file theme={null}
vim qrb-ros-transport-image-type_launch.py
```
```python qrb-ros-transport-image-type_launch.py theme={null}
from launch_ros.actions import ComposableNodeContainer
from launch_ros.descriptions import ComposableNode
from ros2_benchmark import ImageResolution
from ros2_benchmark import ROS2BenchmarkConfig, ROS2BenchmarkTest
def launch_setup(container_prefix, container_sigterm_timeout):
data_loader_node = ComposableNode(
name='DataLoaderNode',
namespace=TestQrbNode.generate_namespace(),
package='ros2_benchmark',
plugin='ros2_benchmark::DataLoaderNode',
)
# QrbPlaybackNode
playback_node = ComposableNode(
name='QrbPlaybackNode',
namespace=TestQrbNode.generate_namespace(),
package='qrb_ros_benchmark',
plugin='qrb_ros::benchmark::QrbPlaybackNode',
parameters=[{
'data_formats': [
'qrb_ros/transport/type/Image'
],
}],
remappings=[
('buffer/input0', '/data_loader_image'),
('input0', '/playback_image')
]
)
# Insert QRB ROS nodes
# QrbMonitorNode
monitor_node = ComposableNode(
name='QrbMonitorNode',
namespace=TestQrbNode.generate_namespace(),
package='qrb_ros_benchmark',
plugin='qrb_ros::benchmark::QrbMonitorNode',
parameters=[{
'monitor_data_format': 'qrb_ros/transport/type/Image',
}]
)
composable_node_container = ComposableNodeContainer(
name='container',
namespace=TestQrbNode.generate_namespace(),
package='rclcpp_components',
executable='component_container_mt',
prefix=container_prefix,
sigterm_timeout=container_sigterm_timeout,
composable_node_descriptions=[
data_loader_node,
playback_node,
monitor_node,
# Insert QRB ROS nodes
],
output='screen'
)
return [composable_node_container]
def generate_test_description():
return TestQrbNode.generate_test_description_with_nsys(launch_setup)
class TestQrbNode(ROS2BenchmarkTest):
config = ROS2BenchmarkConfig(
benchmark_name='Qrb_ros_transport image Test Benchmark',
input_data_path='/path/to/rosbag',
publisher_upper_frequency=100.0,
publisher_lower_frequency=10.0,
playback_message_buffer_size=10
)
def test_benchmark(self):
self.run_benchmark()
```
```bash Start the benchmark theme={null}
source /opt/ros/jazzy/setup.bash
launch_test qrb-ros-transport-image-type_launch.py
```
## Build from source
```bash Install the dependencies theme={null}
sudo apt install ros-jazzy-qrb-ros-transport-image-type
```
```bash Clone the repositories and build theme={null}
mkdir -p ~/ros-ws/src
cd ~/ros-ws/src
git clone https://github.com/qualcomm-qrb-ros/ros2_benchmark.git
git clone https://github.com/qualcomm-qrb-ros/qrb_ros_transport.git
git clone https://github.com/qualcomm-qrb-ros/lib_mem_dmabuf.git
git clone https://github.com/qualcomm-qrb-ros/qrb_ros_imu.git
git clone https://github.com/qualcomm-qrb-ros/dmabuf_transport.git
git clone https://github.com/qualcomm-qrb-ros/qrb_ros_benchmark.git
cd ~/ros-ws/
colcon build
```
```bash Source the workspace theme={null}
source install/setup.bash
```
Run the `qrb-ros-benchmark` according to step 2 of [Run out-of-the-box `qrb_ros_benchmark`](./evaluate-ros-component-performance-with-qrb_ros_benchmark#run-out-of-the-box-qrb_ros_benchmark).