

The Qualcomm® Intelligent Robotics (QIR) SDK for Ubuntu includes components that enable you to develop robotic features on Qualcomm platforms using the Ubuntu OS. It applies to the Ubuntu on Qualcomm IoT platform releases. The QIR SDK provides the following features:
  • Reference Robot Operating System (ROS) packages to develop robotic applications.
  • E2E scenario samples to evaluate robotic platforms.
  • QRB ROS transport
    QRB ROS transport achieves zero-copy transport of ROS messages on Qualcomm robotics platforms.
It’s implemented based on REP 2007, which provides interfaces to define methods for serializing custom types and/or using those types in intra-process communication without conversion. The following topics guide you to use the QIR sample applications for development kits running Ubuntu. They explain how to:
  • Fetch ROS2 and QIR SDK by scripts
  • Run sample applications

Supported development kits

The QIR SDK for Ubuntu supports the following development kits:
The QIR SDK stops the support for RB3 Gen 2 Vision Development Kit from Ubuntu 24.04 x09 release on Qualcomm IoT Platforms. For details, see Install Ubuntu on Qualcomm IoT Platforms.

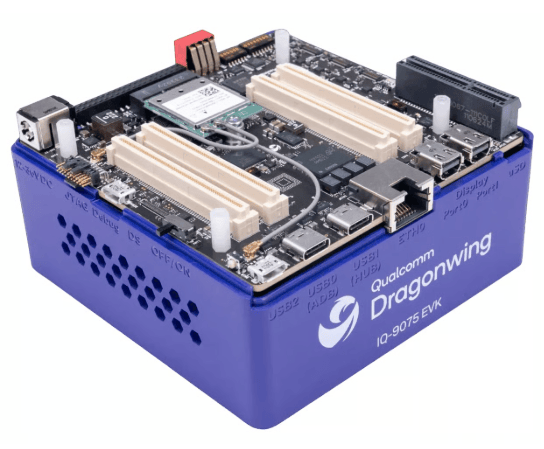
IQ-9075 EVK

Qualcomm® Dragonwing™ IQ-9075 Evaluation Kit (Device overview)iq-9075 EVK
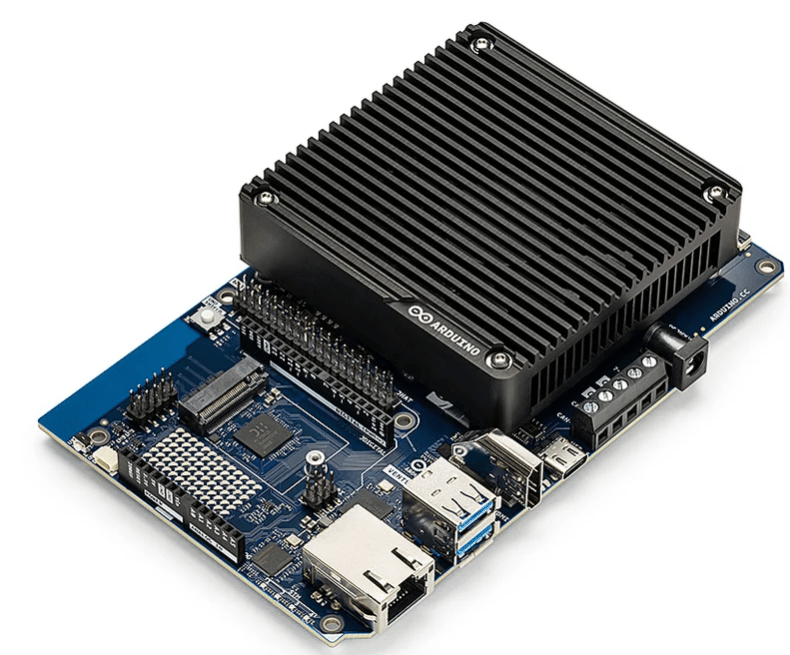
Ventuo Q

Arduino® VENTUNO™ Q (Device overview)Ventuno Q
Architecture

The figure shows the overall software architecture of the QIR SDK for Ubuntu.
QIR SDK layered over ROS2 Jazzy and Canonical Ubuntu 24.04, running on Qualcomm Dragonwing Kits and Arduino Ventuno Q hardware.

QIR SDK software architecture for Ubuntu.

Sample applications

To help you understand the features, the QIR SDK integrates these sample applications. The following table lists the sample application categories and what each one provides.