

引脚定义
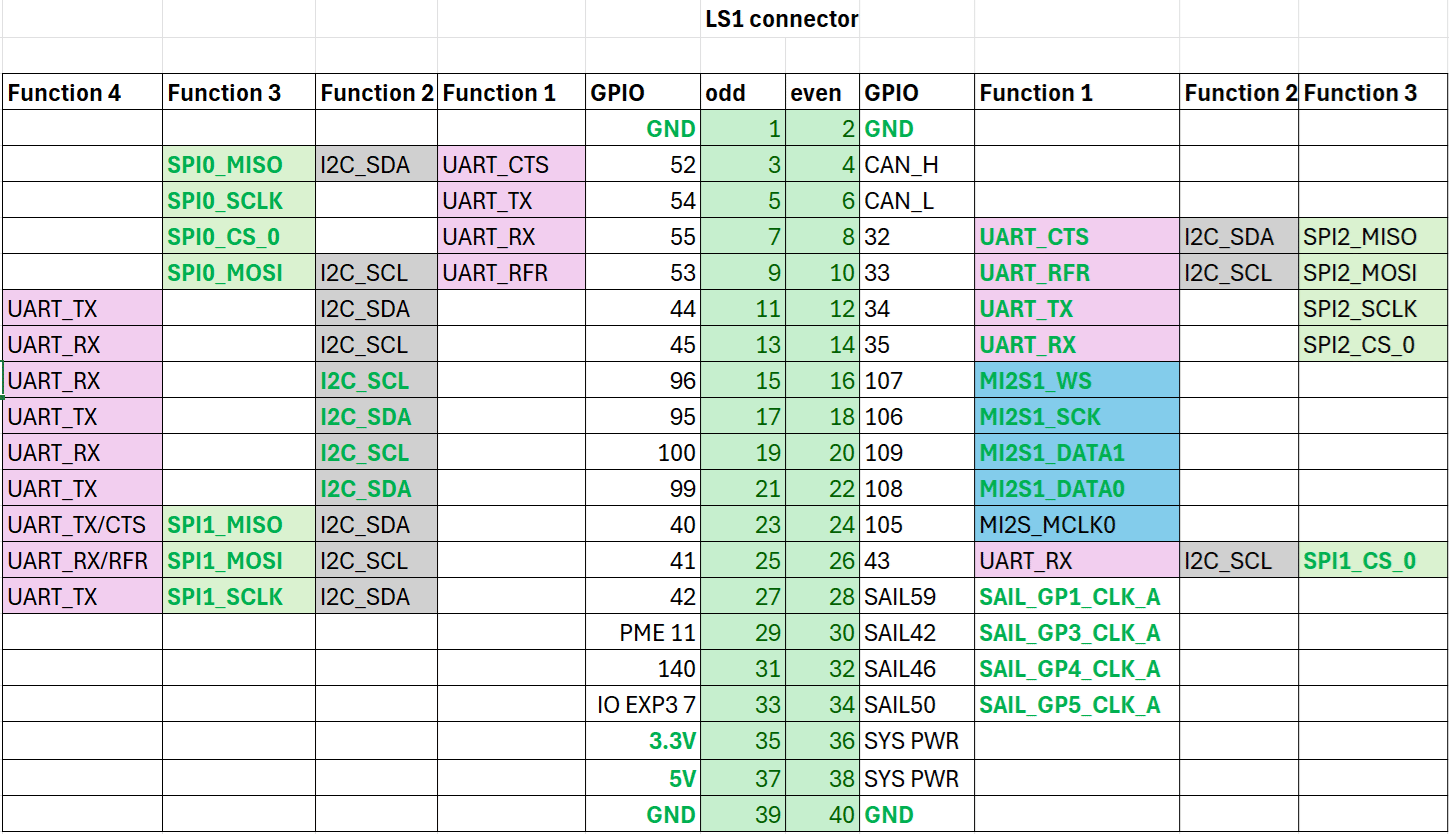
下图展示了 IQ-9075 EVK 40 针 LS 连接器的默认功能。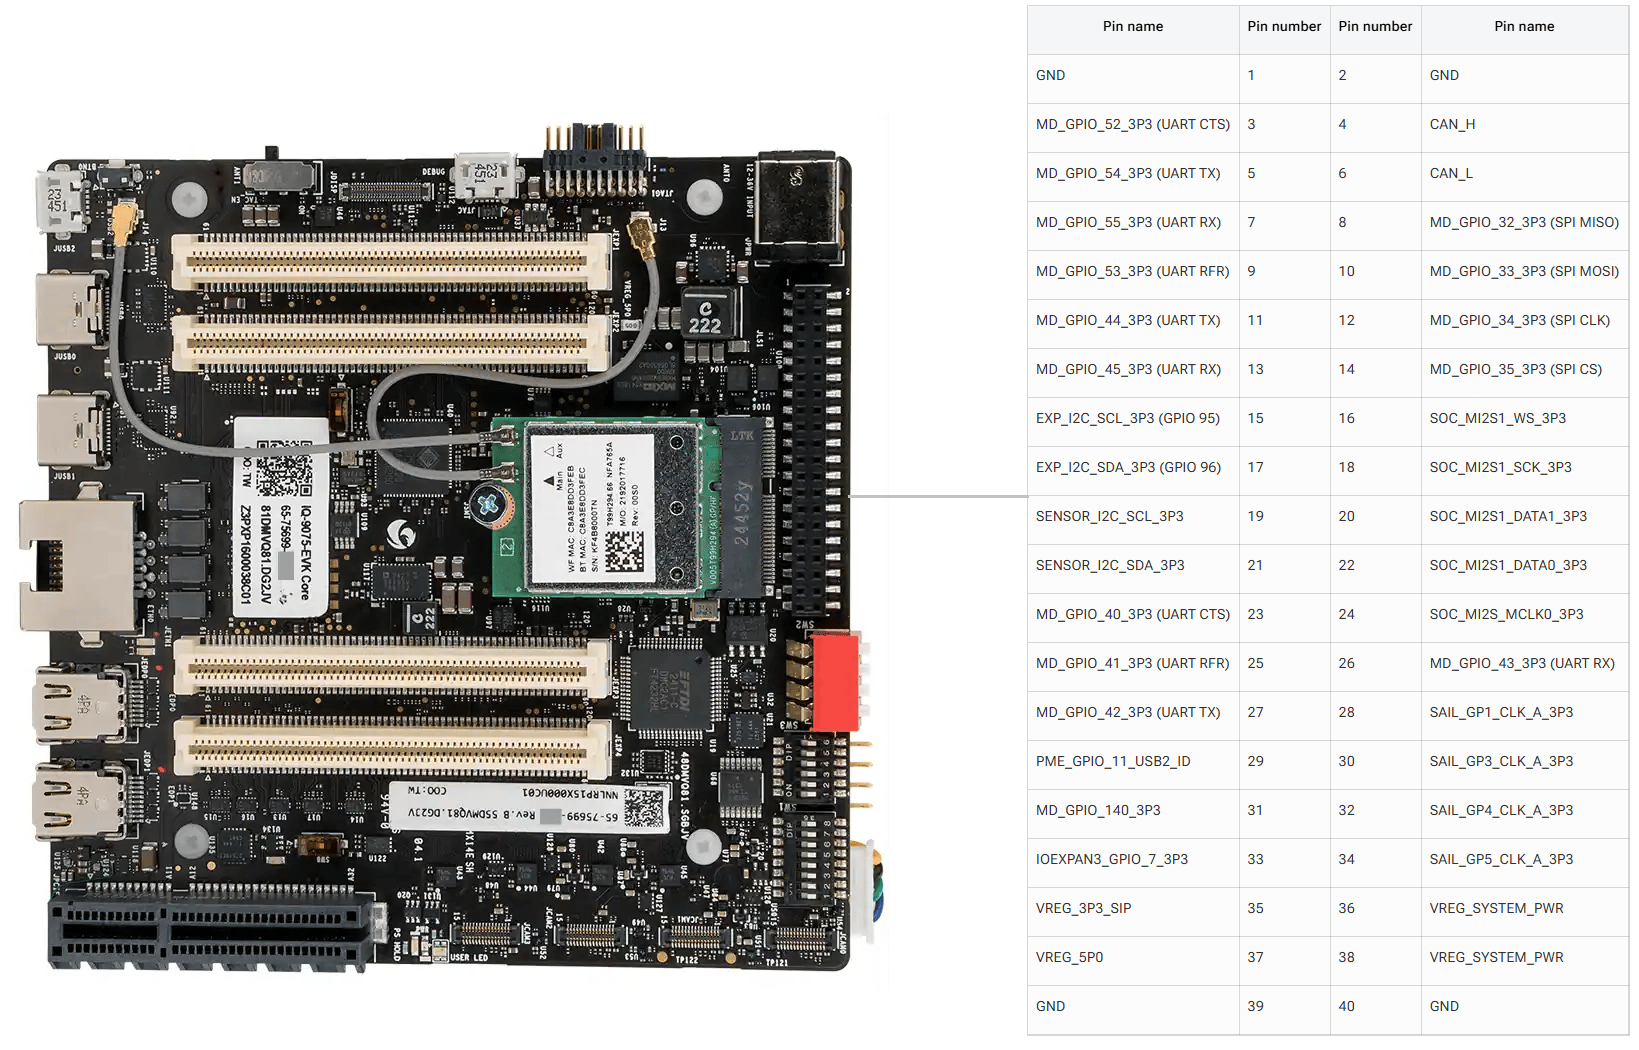
GPIO
以下命令需要 root 权限。使用
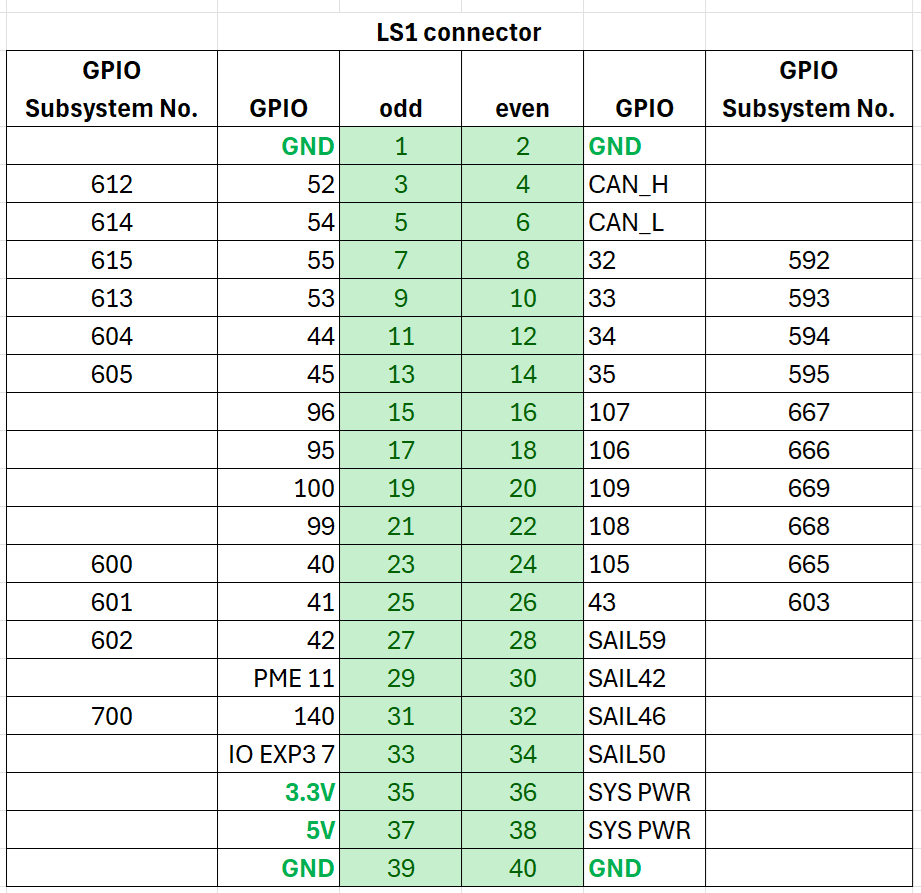
sudo su 切换到 root 用户。确定 GPIO 子系统编号
运行以下命令并查找platform/f000000.pinctrl(gpiochip4)以确定 GPIO 基准编号。对于 IQ-9075,基准值为 560。
cat /sys/kernel/debug/gpio
通过 sysfs 控制 GPIO
1
导出 GPIO
cd /sys/class/gpio
echo 614 > export
2
配置方向和值
cd gpio614
echo out > direction
echo 1 > value
| 属性 | 值 |
|---|---|
direction | in(输入)、out(输出) |
value | 0(低电平)、1(高电平) |
edge | rising、falling、both、none |
3
完成后取消导出
cd ..
echo 614 > unexport
GPIO 代码示例
- C
- Python
以下示例将引脚 5 设置为输出、引脚 7 设置为输入,并循环检测引脚 7 的电平。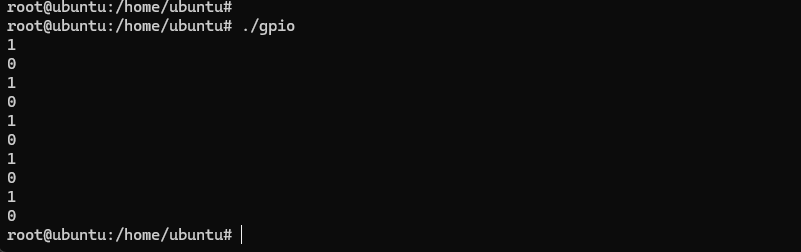
#include <stdio.h>
#include <stdlib.h>
#include <unistd.h>

int out_gpio = 614;
int in_gpio = 615;

int main() {
    char export_path[50] = {};
    char export_command[100] = {};
    snprintf(export_path, sizeof(export_path), "/sys/class/gpio/export");
    snprintf(export_command, sizeof(export_command), "echo %d > %s ", out_gpio, export_path);
    system(export_command);
    snprintf(export_command, sizeof(export_command), "echo %d > %s ", in_gpio, export_path);
    system(export_command);

    char direction_path[50] = {};
    snprintf(direction_path, sizeof(direction_path), "/sys/class/gpio/gpio%d/direction", out_gpio);
    FILE *direction_file = fopen(direction_path, "w");
    if (direction_file == NULL) { perror("Failed to open GPIO direction file"); return -1; }
    fprintf(direction_file, "out");
    fclose(direction_file);

    snprintf(direction_path, sizeof(direction_path), "/sys/class/gpio/gpio%d/direction", in_gpio);
    direction_file = fopen(direction_path, "w");
    if (direction_file == NULL) { perror("Failed to open GPIO direction file"); return -1; }
    fprintf(direction_file, "in");
    fclose(direction_file);

    char value_in_path[50] = {};
    char value_out_path[50] = {};
    char cat_command[100] = {};
    snprintf(value_out_path, sizeof(value_out_path), "/sys/class/gpio/gpio%d/value", out_gpio);
    snprintf(value_in_path, sizeof(value_in_path), "/sys/class/gpio/gpio%d/value", in_gpio);
    snprintf(cat_command, sizeof(cat_command), "cat %s", value_in_path);

    FILE *value_out_file = fopen(value_out_path, "w");
    if (value_out_file == NULL) { perror("Failed to open GPIO value file"); return -1; }

    for (int i = 0; i < 5; i++) {
        fprintf(value_out_file, "1"); fflush(value_out_file);
        system(cat_command); sleep(1);
        fprintf(value_out_file, "0"); fflush(value_out_file);
        system(cat_command); sleep(1);
    }
    fclose(value_out_file);

    char unexport_path[50] = {};
    char unexport_command[100] = {};
    snprintf(unexport_path, sizeof(unexport_path), "/sys/class/gpio/unexport");
    snprintf(unexport_command, sizeof(unexport_command), "echo %d > %s ", out_gpio, unexport_path);
    system(unexport_command);
    snprintf(unexport_command, sizeof(unexport_command), "echo %d > %s ", in_gpio, unexport_path);
    system(unexport_command);
    return 0;
}
1
编译
gcc gpio.c -o gpio
2
连接引脚
使用杜邦线短接引脚 5 和引脚 7。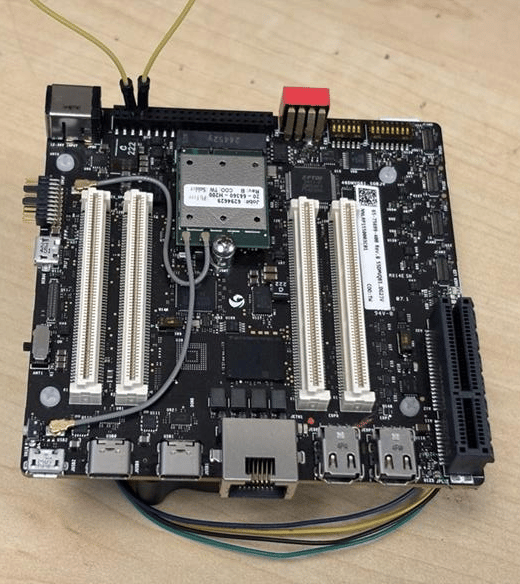
注意引脚顺序。请勿短接电源和地引脚 — 这可能会损坏板卡。
3
运行
./gpio
安装 以下示例将引脚 5 设置为输出、引脚 7 设置为输入,并循环检测引脚 7 的电平。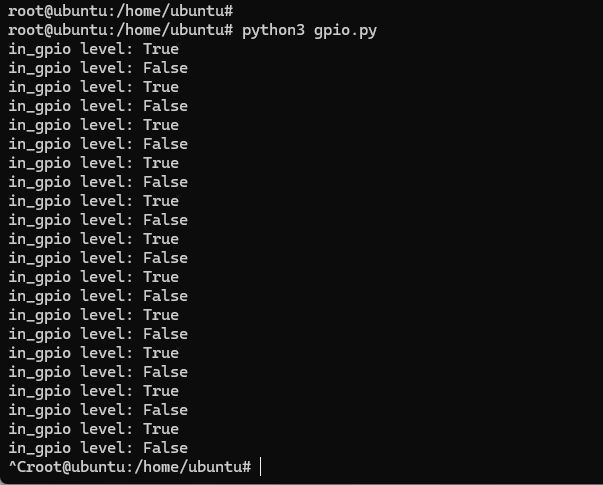
python3-periphery:apt install python3-pip
apt install python3-periphery
from periphery import GPIO
import time

out_gpio = GPIO(614, "out")
in_gpio = GPIO(615, "in")

try:
    while True:
        try:
            out_gpio.write(True)
            print(f"in_gpio level: {in_gpio.read()}")
            out_gpio.write(False)
            print(f"in_gpio level: {in_gpio.read()}")
            time.sleep(1)
        except KeyboardInterrupt:
            out_gpio.write(False)
            break
except IOError:
    print("Error")
finally:
    out_gpio.close()
    in_gpio.close()
1
连接引脚
使用杜邦线短接引脚 5 和引脚 7。
注意引脚顺序。请勿短接电源和地引脚 — 这可能会损坏板卡。
2
运行
python3 gpio.py
UART
引脚 5 和 7 默认配置为 UART(GPIO 线 54 和 55,映射到uart12 = qup1_se5 (0xa98000))。
按照修改串行引擎节点的步骤启用 UART 接口。启用后,设备节点出现在 /dev/ttyHS3。
ubuntu@ubuntu:/dev$ ls -al ttyHS3
crw-rw---- 1 root dialout 236, 2 Nov 25 18:16 ttyHS3
- Shell
- C
- Python
1
连接引脚
使用杜邦线短接引脚 5 和引脚 7。
注意引脚顺序。请勿短接电源和地引脚 — 这可能会损坏板卡。
2
配置 UART
sudo stty -F /dev/ttyHS3 ispeed 115200 ospeed 115200
sudo stty -F /dev/ttyHS3 115200 -echo -icanon -isig -iexten -icrnl -ixon -opost
3
打开两个 SSH 终端
终端 1(RX):终端 2(TX):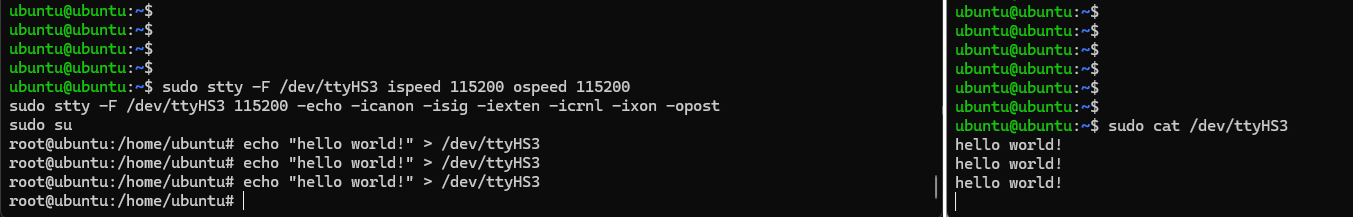
sudo cat /dev/ttyHS3
sudo su
echo "hello world!" > /dev/ttyHS3
以下 C 程序通过 UART 发送和接收数据,包含完整的原始模式配置和可选的 PM 时钟投票支持。
#define _GNU_SOURCE
#include <errno.h>
#include <fcntl.h>
#include <getopt.h>
#include <poll.h>
#include <signal.h>
#include <stdio.h>
#include <stdlib.h>
#include <string.h>
#include <termios.h>
#include <unistd.h>
#include <sys/ioctl.h>

#ifndef TIOCPMGET
#define TIOCPMGET  0x544D
#endif
#ifndef TIOCPMPUT
#define TIOCPMPUT  0x544E
#endif

static volatile sig_atomic_t g_stop = 0;
static void on_sigint(int sig) { (void)sig; g_stop = 1; }

static speed_t baud_to_speed(int baud) {
    switch (baud) {
        case 9600:   return B9600;
        case 19200:  return B19200;
        case 38400:  return B38400;
        case 57600:  return B57600;
        case 115200: return B115200;
        case 230400: return B230400;
        default:     return 0;
    }
}

static void uart_clock_vote_on(int fd) {
    if (ioctl(fd, TIOCPMGET, 0) < 0 && errno != ENOTTY)
        fprintf(stderr, "WARN: ioctl(TIOCPMGET) failed: %s\n", strerror(errno));
}

static void uart_clock_vote_off(int fd) {
    if (ioctl(fd, TIOCPMPUT, 0) < 0 && errno != ENOTTY)
        fprintf(stderr, "WARN: ioctl(TIOCPMPUT) failed: %s\n", strerror(errno));
}

static int configure_serial(int fd, int baud, int rx_block_forever) {
    struct termios tty;
    if (tcgetattr(fd, &tty) != 0) { perror("tcgetattr"); return -1; }
    cfmakeraw(&tty);
    speed_t spd = baud_to_speed(baud);
    if (spd == 0) { fprintf(stderr, "Unsupported baud rate: %d\n", baud); return -1; }
    cfsetispeed(&tty, spd); cfsetospeed(&tty, spd);
    tty.c_cflag &= ~(PARENB | CSTOPB | CSIZE); tty.c_cflag |= CS8 | CLOCAL | CREAD | ~CRTSCTS;
    tty.c_iflag &= ~(IXON | IXOFF | IXANY);
    tty.c_cc[VMIN]  = rx_block_forever ? 1 : 0;
    tty.c_cc[VTIME] = 0;
    if (tcsetattr(fd, TCSANOW, &tty) != 0) { perror("tcsetattr"); return -1; }
    tcflush(fd, TCIOFLUSH);
    return 0;
}

int main(int argc, char **argv) {
    struct sigaction sa; memset(&sa, 0, sizeof(sa));
    sa.sa_handler = on_sigint; sigaction(SIGINT, &sa, NULL);

    const char *device = "/dev/ttyHS3";
    int baud = 115200, rx_mode = 0;
    const char *tx = "hello world!\n";

    int c;
    while ((c = getopt(argc, argv, "d:b:t:Rh")) != -1) {
        switch (c) {
            case 'd': device = optarg; break;
            case 'b': baud = atoi(optarg); break;
            case 't': tx = optarg; break;
            case 'R': rx_mode = 1; break;
        }
    }

    int fd = open(device, O_RDWR | O_NOCTTY);
    if (fd < 0) { fprintf(stderr, "Failed to open %s: %s\n", device, strerror(errno)); return 1; }
    if (configure_serial(fd, baud, rx_mode) != 0) { close(fd); return 1; }

    if (rx_mode) {
        struct pollfd pfd = { .fd = fd, .events = POLLIN };
        uart_clock_vote_on(fd);
        printf("RX: waiting on %s (Ctrl+C to stop)...\n", device);
        while (!g_stop) {
            if (poll(&pfd, 1, -1) < 0) { if (errno == EINTR) continue; break; }
            if (pfd.revents & POLLIN) {
                unsigned char buf[512];
                ssize_t r = read(fd, buf, sizeof(buf));
                if (r > 0) { fwrite(buf, 1, r, stdout); fflush(stdout); }
            }
        }
        uart_clock_vote_off(fd);
    } else {
        uart_clock_vote_on(fd);
        ssize_t w = write(fd, tx, strlen(tx));
        printf("TX (%zd bytes) on %s: %s", w, device, tx);
        uart_clock_vote_off(fd);
    }
    close(fd);
    return 0;
}
1
编译
gcc -O2 -Wall -o uarttest uart.c
2
打开两个 SSH 终端
终端 1(RX):终端 2(TX):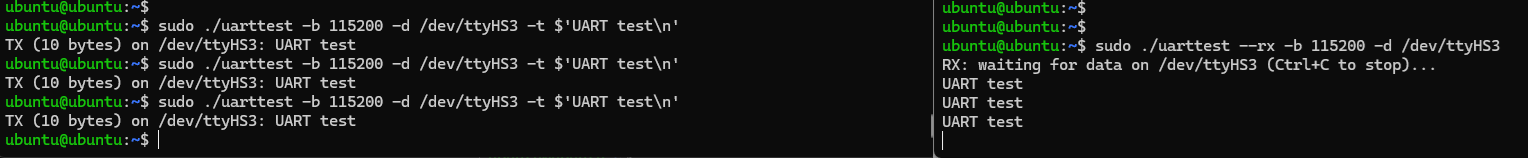
sudo ./uarttest --rx -b 115200 -d /dev/ttyHS3
sudo ./uarttest -b 115200 -d /dev/ttyHS3 -t $'UART test\n'
以下 Python 脚本使用原始 termios 配置通过 UART 发送和接收数据。
#!/usr/bin/env python3
import argparse, errno, fcntl, os, select, signal, sys, termios

TIOCPMGET = 0x544D
TIOCPMPUT = 0x544E
STOP = False

def sigint_handler(signum, frame):
    global STOP
    STOP = True

signal.signal(signal.SIGINT, sigint_handler)

def vote_clock_on(fd):
    try: fcntl.ioctl(fd, TIOCPMGET, 0)
    except OSError as e:
        if e.errno != errno.ENOTTY: print(f"WARN: {e}", file=sys.stderr)

def vote_clock_off(fd):
    try: fcntl.ioctl(fd, TIOCPMPUT, 0)
    except OSError as e:
        if e.errno != errno.ENOTTY: print(f"WARN: {e}", file=sys.stderr)

def set_raw_8n1(fd, baud, rx_block_forever):
    attrs = termios.tcgetattr(fd)
    iflag, oflag, cflag, lflag, ispeed, ospeed, cc = attrs
    iflag &= ~(termios.IGNBRK | termios.BRKINT | termios.PARMRK | termios.ISTRIP |
               termios.INLCR | termios.IGNCR | termios.ICRNL | termios.IXON | termios.IXOFF | termios.IXANY)
    oflag &= ~termios.OPOST
    lflag &= ~(termios.ECHO | termios.ECHONL | termios.ICANON | termios.ISIG | termios.IEXTEN)
    cflag &= ~(termios.CSIZE | termios.PARENB | termios.CSTOPB)
    cflag |= termios.CS8 | termios.CREAD | termios.CLOCAL
    if hasattr(termios, "CRTSCTS"): cflag &= ~termios.CRTSCTS
    baud_map = {9600: termios.B9600, 19200: termios.B19200, 38400: termios.B38400,
                57600: termios.B57600, 115200: termios.B115200, 230400: termios.B230400}
    if baud not in baud_map: raise ValueError(f"Unsupported baud rate: {baud}")
    ispeed = ospeed = baud_map[baud]
    cc[termios.VMIN] = 1 if rx_block_forever else 0
    cc[termios.VTIME] = 0
    termios.tcsetattr(fd, termios.TCSANOW, [iflag, oflag, cflag, lflag, ispeed, ospeed, cc])
    termios.tcflush(fd, termios.TCIOFLUSH)

def rx_forever(fd, device):
    vote_clock_on(fd)
    print(f"RX: waiting on {device} (Ctrl+C to stop)...")
    while not STOP:
        rlist, _, _ = select.select([fd], [], [], 1.0)
        if rlist:
            data = os.read(fd, 512)
            if data: sys.stdout.buffer.write(data); sys.stdout.buffer.flush()
    vote_clock_off(fd)
    print("\nRX: stopped.")

def tx_once(fd, device, payload):
    vote_clock_on(fd)
    n = os.write(fd, payload)
    sys.stdout.write(f"TX ({n} bytes) on {device}: ")
    sys.stdout.buffer.write(payload); sys.stdout.buffer.flush()
    vote_clock_off(fd)

def main():
    p = argparse.ArgumentParser()
    p.add_argument("-d", "--device", default="/dev/ttyHS3")
    p.add_argument("-b", "--baud", type=int, default=115200)
    p.add_argument("-t", "--tx", default="hello world!\n")
    p.add_argument("-R", "--rx", action="store_true")
    args = p.parse_args()
    fd = os.open(args.device, os.O_RDWR | os.O_NOCTTY)
    set_raw_8n1(fd, args.baud, rx_block_forever=args.rx)
    if args.rx: rx_forever(fd, args.device)
    else: tx_once(fd, args.device, args.tx.encode("utf-8", errors="replace"))
    os.close(fd)

if __name__ == "__main__":
    raise SystemExit(main())
1
打开两个 SSH 终端
终端 1(RX):终端 2(TX):
sudo python3 uart_tool.py --rx -b 115200
sudo python3 uart_tool.py -b 115200 -t $'UART test\n'
I2C
I2C(内部集成电路总线)是一种用于 IC 间控制的双向 2 线总线。总线上的每个设备都有唯一的地址。I2C 核心支持多控制器模式、10 位目标寻址和 10 位可扩展寻址。 引脚 8 和 10 默认配置为 I2C(GPIO 线 32 和 33,映射到i2c4 = qup0_se4 (0x990000))。
按照修改串行引擎节点的步骤启用 I2C 接口。启用后,验证设备节点:
ls /dev/i2c*
# Expected: /dev/i2c-18  /dev/i2c-19  /dev/i2c-20  /dev/i2c-21  /dev/i2c-22  /dev/i2c-23  /dev/i2c-24  /dev/i2c-25
- Shell
- C
- Python
1
安装 i2c-tools
sudo apt install -y i2c-tools
2
列出 I2C 适配器
i2cdetect -l
3
将适配器映射到设备树节点
ls -l /sys/class/i2c-adapter/i2c-*
4
扫描总线 20 上的设备
i2cdetect -a -y -r 20
5
读/写设备寄存器
# Read all registers of device at address 0x38
i2cdump -f -y 1 0x38

# Write 0xaa to register 0x01
i2cset -f -y 1 0x38 0x01 0xaa

# Read register 0x01
i2cget -f -y 1 0x38 0x01
以下示例向 I2C 地址为
0x38 的设备的地址 0x01 写入 0xaa。#include <stdio.h>
#include <stdlib.h>
#include <stdint.h>
#include <fcntl.h>
#include <unistd.h>
#include <linux/i2c-dev.h>
#include <sys/ioctl.h>
#define I2C_DEVICE_PATH "/dev/i2c-1"
int main() {
uint8_t data[2] = {0x01, 0xaa};
int i2c_file;
if ((i2c_file = open(I2C_DEVICE_PATH, O_RDWR)) < 0) {
perror("Failed to open I2C device");
return -1;
}
ioctl(i2c_file, I2C_TENBIT, 0);
ioctl(i2c_file, I2C_RETRIES, 5);
printf("i2cdetect addr: ");
for (int x = 0; x < 0x7f; x++) {
if (ioctl(i2c_file, I2C_SLAVE, x) < 0) {
perror("Failed to set I2C slave address");
close(i2c_file);
return -1;
}
if (write(i2c_file, data, 2) == 2)
printf("0x%x,", x);
}
close(i2c_file);
printf("\r\n");
return 0;
}
1
编译
gcc i2c.c -o i2c
2
将传感器连接到引脚 11 和 13,然后运行
./i2c
安装 以下示例向 I2C 地址为 将传感器连接到引脚 11 和 13,然后运行:
python3-smbus:sudo apt install python3-smbus
0x38 的设备的地址 0x01 写入 0xaa。import smbus
def main():
data = [0x01, 0xaa]
i2c_bus = None
try:
i2c_bus = smbus.SMBus(1)
print("i2cdetect addr: ", end="")
for address in range(0x7F):
try:
i2c_bus.write_i2c_block_data(address, 0, data)
print("0x{:02X},".format(address), end="")
except OSError:
pass
print()
except Exception as e:
print(f"An error occurred: {e}")
finally:
if i2c_bus:
i2c_bus.close()
if __name__ == "__main__":
main()
python3 i2c.py
SPI
SPI(串行外设接口)是一种同步全双工 4 线串行总线。 引脚 11 和 13 默认配置为 SPI(GPIO 线 44 和 45,映射到spi10 = qup1_se3 (0xa8c000))。
按照修改串行引擎节点的步骤启用 SPI 接口。
- C
- Python
以下示例通过 SPI 回环发送和接收数据。
#include <stdio.h>
#include <stdlib.h>
#include <stdint.h>
#include <fcntl.h>
#include <unistd.h>
#include <linux/spi/spidev.h>
#include <sys/ioctl.h>

#define SPI_DEVICE_PATH "/dev/spidev12.0"

int main() {
    int spi_file;
    uint8_t tx_buffer[50] = "hello world!";
    uint8_t rx_buffer[50];

    if ((spi_file = open(SPI_DEVICE_PATH, O_RDWR)) < 0) {
        perror("Failed to open SPI device");
        return -1;
    }

    uint8_t mode = SPI_MODE_0, bits = 8;
    ioctl(spi_file, SPI_IOC_WR_MODE, &mode);
    ioctl(spi_file, SPI_IOC_WR_BITS_PER_WORD, &bits);

    struct spi_ioc_transfer transfer = {
        .tx_buf = (unsigned long)tx_buffer,
        .rx_buf = (unsigned long)rx_buffer,
        .len = sizeof(tx_buffer),
        .speed_hz = 1000000,
        .bits_per_word = 8,
    };

    if (ioctl(spi_file, SPI_IOC_MESSAGE(1), &transfer) < 0) {
        perror("Failed to perform SPI transfer");
        close(spi_file);
        return -1;
    }

    printf("tx_buffer:\n %s\n", tx_buffer);
    printf("rx_buffer:\n %s\n", rx_buffer);
    close(spi_file);
    return 0;
}
1
编译
gcc spi.c -o spi
2
使用杜邦线短接引脚 11 和引脚 13(回环),然后运行
./spi
安装
python3-spidev:sudo apt install python3-spidev
import spidev

def main():
    tx_buffer = [ord(c) for c in "hello world!"]
    try:
        spi = spidev.SpiDev()
        spi.open(12, 0)
        spi.max_speed_hz = 1000000
        rx_buffer = spi.xfer2(tx_buffer[:])
        print("tx_buffer:\n", ''.join(map(chr, tx_buffer)))
        print("rx_buffer:\n", ''.join(map(chr, rx_buffer)))
    except Exception as e:
        print(f"An error occurred: {e}")
    finally:
        spi.close()

if __name__ == "__main__":
    main()
1
使用杜邦线短接引脚 11 和引脚 13(回环),然后运行
python3 spi.py