

qrb_ros_benchmark builds on ros2_benchmark and extends it with specialized components for benchmarking QRB ROS transport types, including:
- QRB transport types (Image, IMU, PointCloud2)
- DMABuf transport types (Image, PointCloud2)
- Standard ROS message types
Software structure
The following figure shows the software structure ofqrb_ros_benchmark.
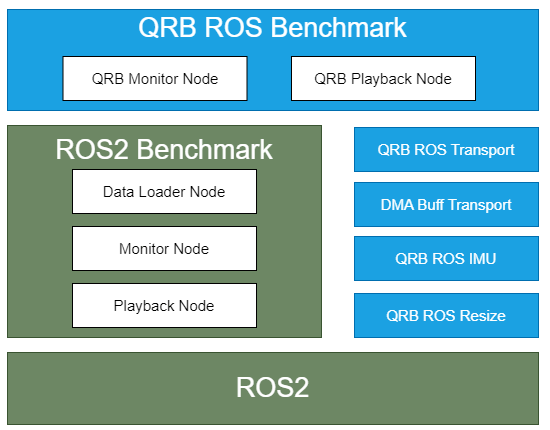
Software structure of qrb_ros_benchmark.
qrb_ros_benchmark:
QRB transport types:
-
qrb_ros/transport/type/Image -
qrb_ros/transport/type/Imu -
qrb_ros/transport/type/PointCloud2 -
qrb_ros_tensor_list_msgs::msg::TensorList
-
dmabuf_transport/type/Image -
dmabuf_transport/type/PointCloud2
Prerequisites
You have set up the device, installed ROS2 Jazzy and the Qualcomm Intelligent Robotics (QIR) SDK on the device according to Install the QIR SDK.Run out-of-the-box qrb_ros_benchmark
1
Install the qrb_ros_benchmark packages
Install the packages
2
Create a minimum template for evaluating qrb_ros/transport/type/Image
Create the launch file
qrb-ros-transport-image-type_launch.py
qrb-ros-transport-image-type_launch.py
qrb-ros-transport-image-type_launch.py
3
Start the qrb-ros-transport-image-type benchmark
Start the benchmark
Build from source
1
Install dependencies
Install the dependencies
2
Download the source code and build with colcon
Clone the repositories and build
3
Run and debug
Source the workspace
4
Run the qrb-ros-benchmark
Run the
qrb-ros-benchmark according to step 2 of Run out-of-the-box qrb_ros_benchmark.