

qrb_ros_transport sends image DMA buffer file descriptors (fd) between ROS nodes, rather than sending the image data itself.
Hardware accelerators, such as cameras, GPUs, and EVA, share image data zero-copy through mmap DMA buffers.
Pipeline flow for qrb_ros_transport
The following figure shows the pipeline flow for qrb_ros_transport.
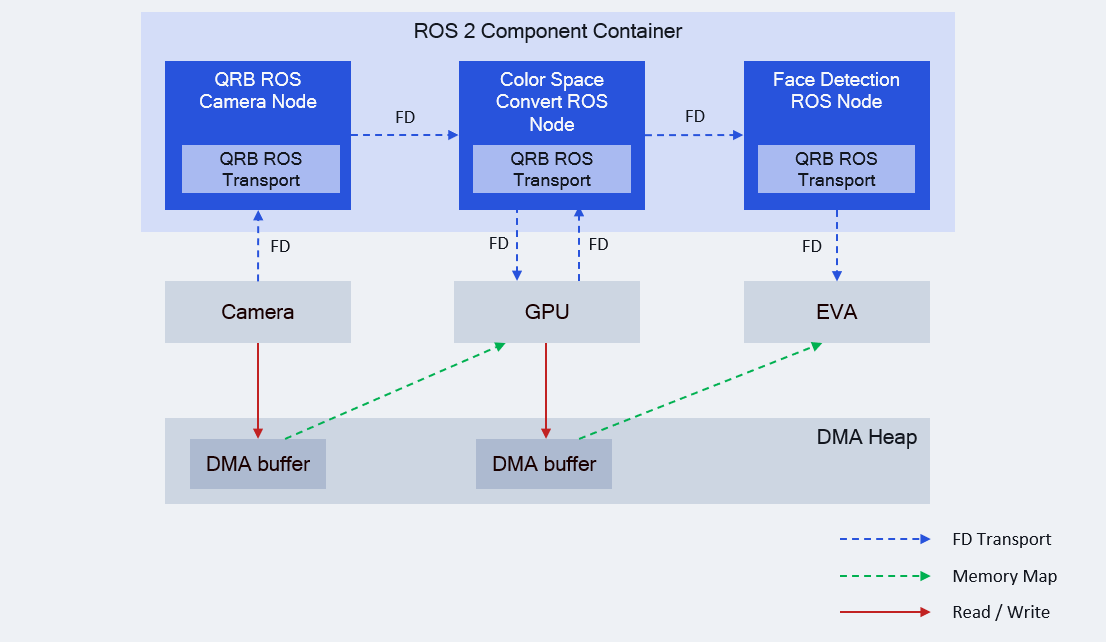
The qrb_ros_transport pipeline.
Prerequisites
You have set up the device, installed ROS2 Jazzy and the Qualcomm Intelligent Robotics (QIR) SDK on the device according to Install the QIR SDK.Run out-of-the-box qrb_ros_transport
1
Install the qrb_ros_transport packages
Install the packages
2
Use qrb_ros::transport::type::Image
For example:
-
Add the dependencies in your
package.xml:package.xml -
Use
ament_cmake_autoto find dependencies in yourCMakeLists.txt:CMakeLists.txt -
Use the adapted types in your ROS node.
Use the adapted image type
Build from source
Build from the source ofqrb_ros_transport and run this application.
1
Install dependencies
Install the dependencies
2
Clone the repository to the device
Clone the repository
3
Build the sample application
Build the workspace