

qrb_ros_nn_inference package provides AI-based perception for robotics applications. It provides the following:
-
Model inference API which supports three model formats:
.tflite,.so,.bin - Model inference acceleration based on Qualcomm platforms
Architecture of qrb_ros_nn_inference
The following figure shows the architecture of qrb_ros_nn_interface.
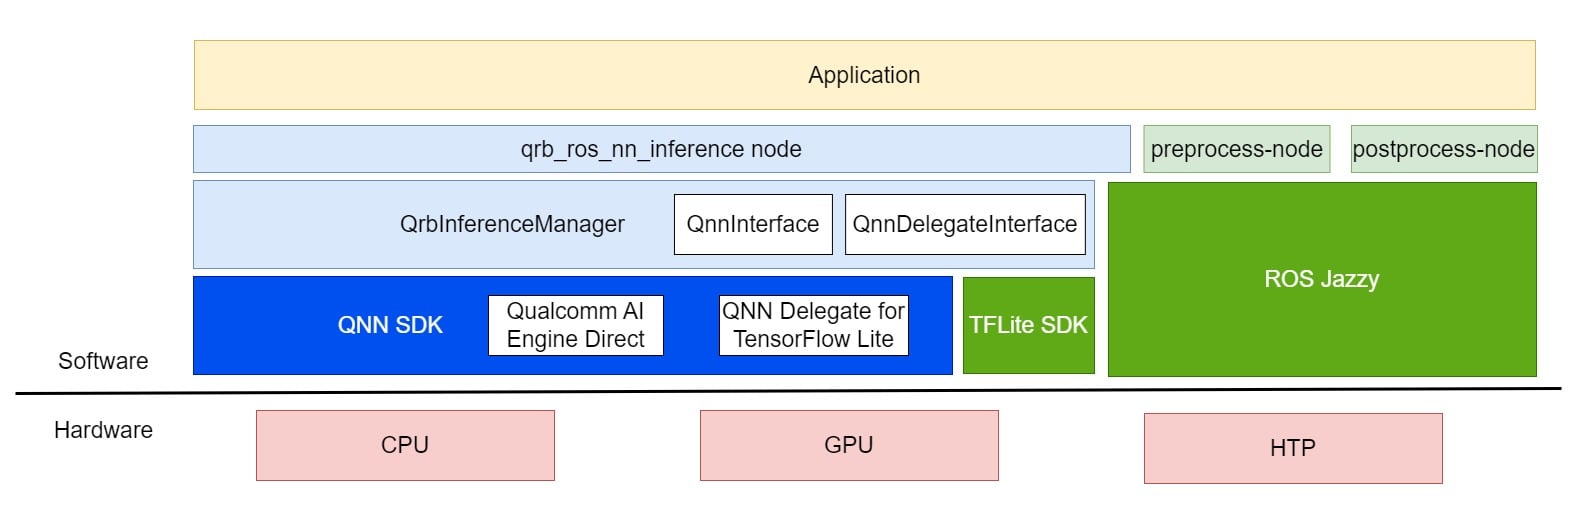
Architecture of qrb_ros_nn_inference.
qrb_ros_nn_inference is a ROS2 package based on qrb_inference_manager, which is a C++ library encapsulating the APIs of Qualcomm AI Engine Direct and Qualcomm Neural Network (QNN) Delegate for TensorFlow Lite.
qrb_ros_nn_inference receives data from a specific topic, then without any processing, directly uses the received data for model inference. Then, the results of the model inference are sent out directly through another specific topic.
ROS node parameters
The following table describes the ROS node parameters forqrb_ros_nn_inference.
ROS topics
The following table describes the ROS topics used byqrb_ros_nn_inference.
Prerequisites
You have set up the device, installed ROS2 Jazzy and Qualcomm Intelligent Robotics (QIR) SDK on the device according to Install the QIR SDK.Run out-of-the-box qrb_ros_nn_inference
1
Install the qrb_ros_transport packages
Install the packages
2
Prepare the preprocess node and postprocess node for model inference
Download the test nodes
3
Test qrb_ros_nn_inference with the YOLOv8 detection model
a. Download the c. Point out the raw image path and model path in d. Build the preprocess node and postprocess node.
yolov8.tflite model by following QC AI hub Getting Started.b. Download the test image for object detection.~/ros-ws/src/qrb_ros_nn_inference/test/qrb_ros_post_process/launch/nn_node_test.launch.py.nn_node_test.launch.py
Build and run the inference
~/ros-ws/src/qrb_ros_nn_inference/test/qrb_ros_post_process/inference_result.
Build and run qrb_ros_nn_inference
1
Install dependencies
Install the dependencies
2
Clone the repository to the device
Download the source code
3
Build and run qrb_ros_nn_inference
Build and launch