

qrb_ros_interfaces collection serves as a centralized repository for all QRB ROS related communication interfaces, ensuring standardization and consistency across various QRB ROS nodes.
Each package within the collection provides specific interface definitions crucial for enabling interoperability and efficient data exchange between components interacting with QRB hardware or software.
The following table lists the interface packages currently included in this collection, with the status, description, and interface types of each package.
Prerequisites
You have set up the device, installed ROS2 Jazzy and the Qualcomm Intelligent Robotics (QIR) SDK on the device according to Install the QIR SDK.Run out-of-the-box qrb_ros_interfaces
1
Install the qrb_ros_interfaces packages
Install the packages
2
Use this package
List the package interfaces
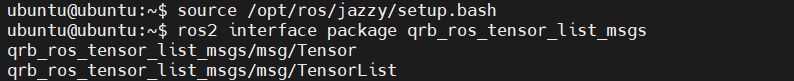
3
Echo scan in another terminal
Show the Tensor message definition
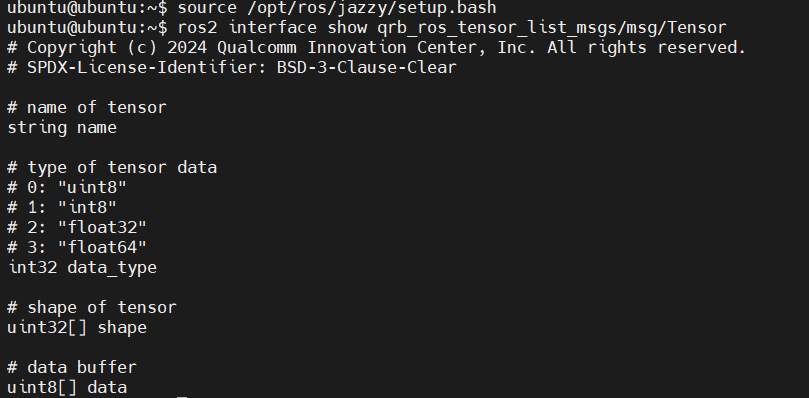
Build and run qrb_ros_interfaces
1
Install dependencies
Install the dependencies
2
Clone the repository to the device
Clone the repository
3
Resolve dependencies
Resolve the dependencies
4
Build and run
Build the workspace
5
Open a new terminal, go to qrb_ros_ws, and source the setup files
Source the setup files and inspect the interfaces